|
I am a Ph.D. candidate in Data Science at
|
|
|
|
† Equal contribution. * Corresponding author or Project lead.
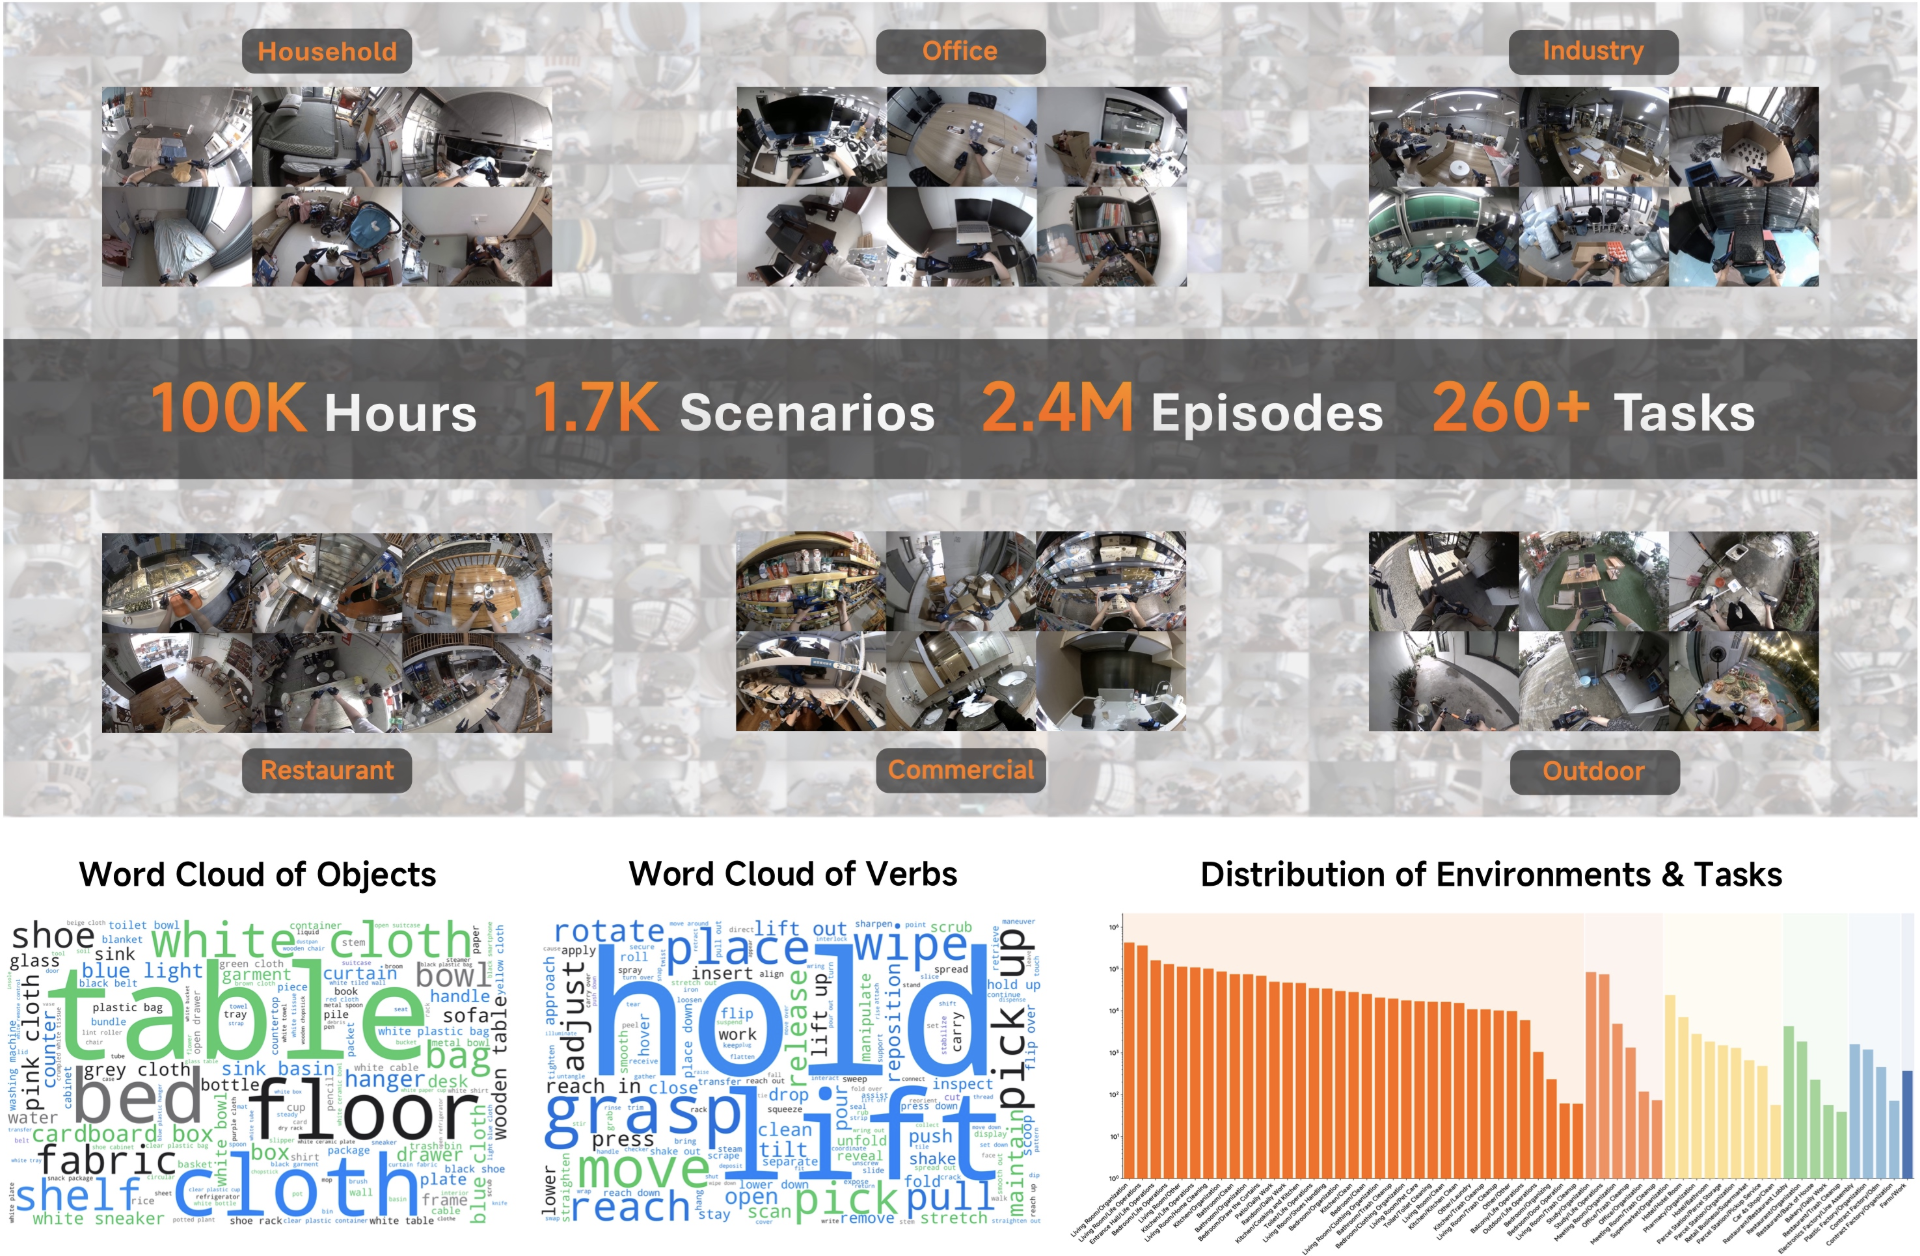
|
Technical Report |
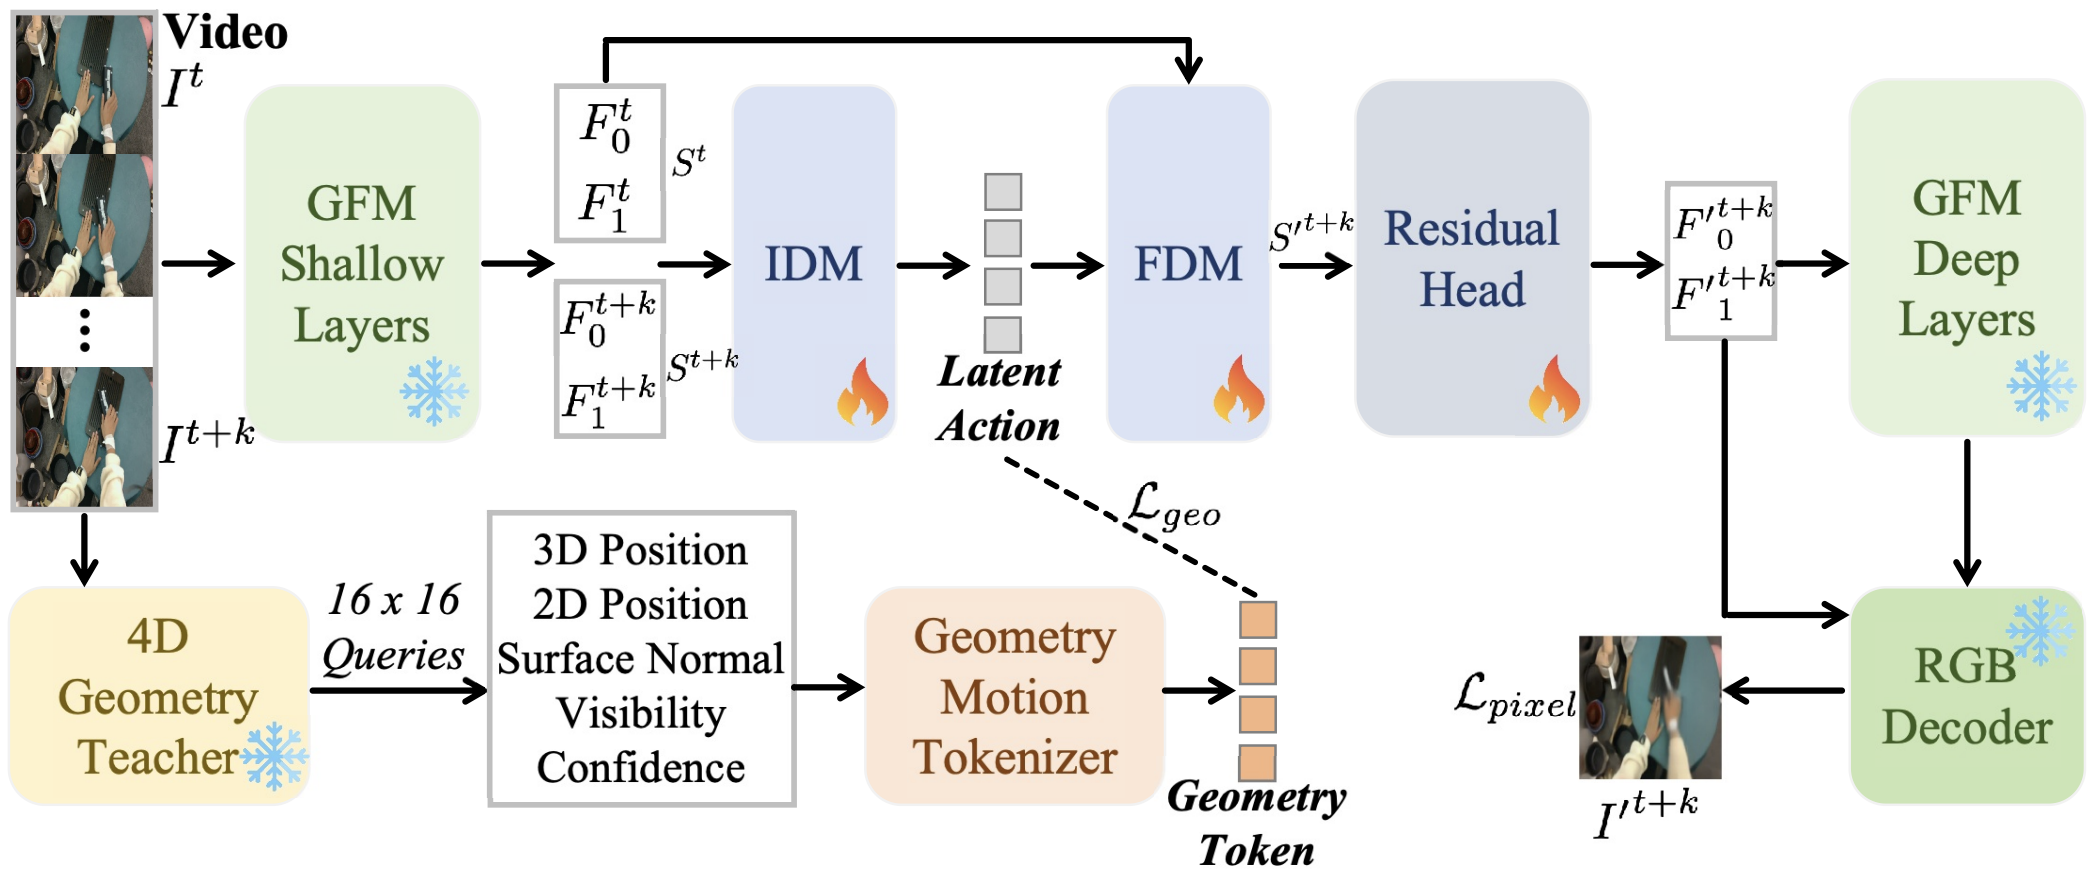
|
Preprint |
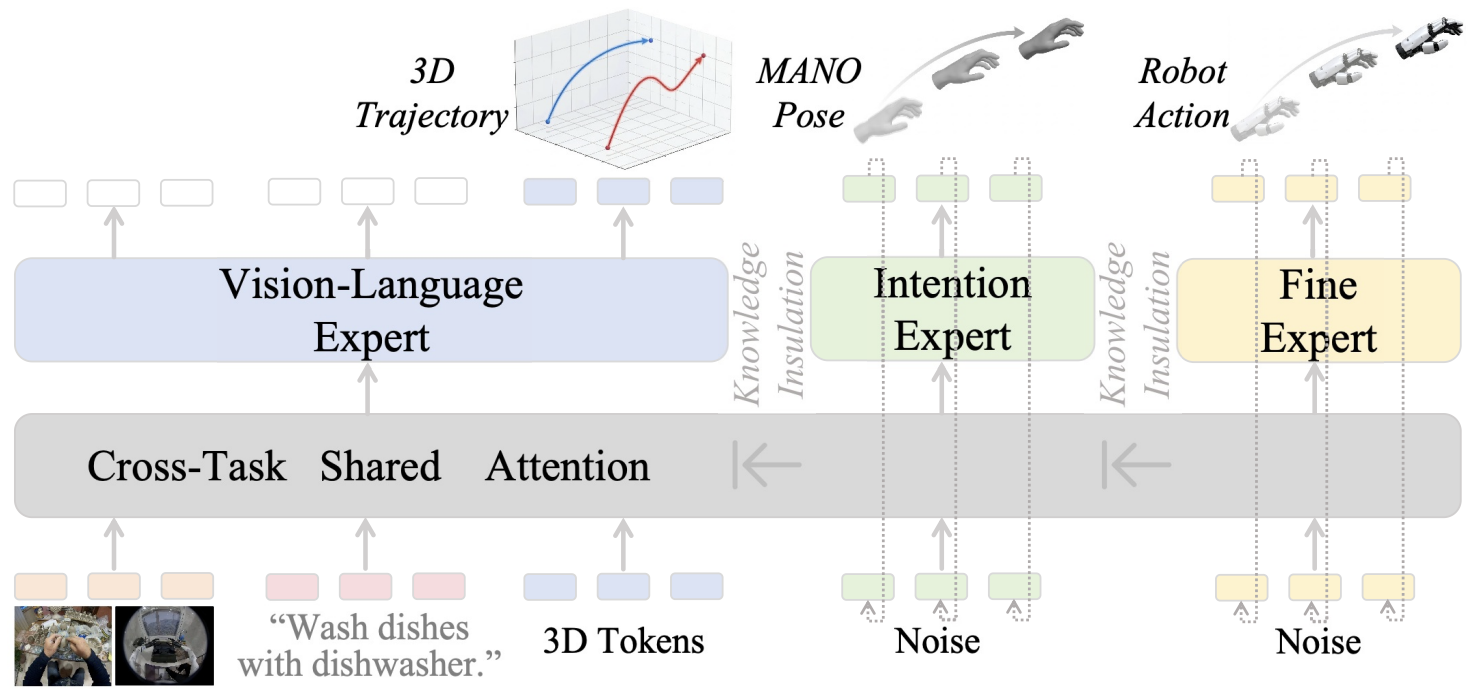
|
NeurIPS 2026 |
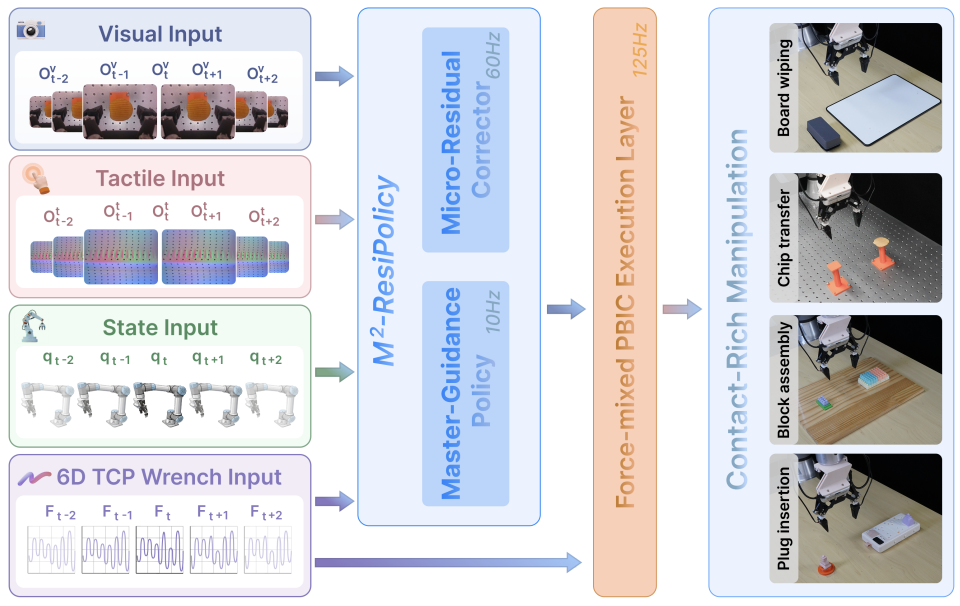
|
IEEE RA-L 2026 |
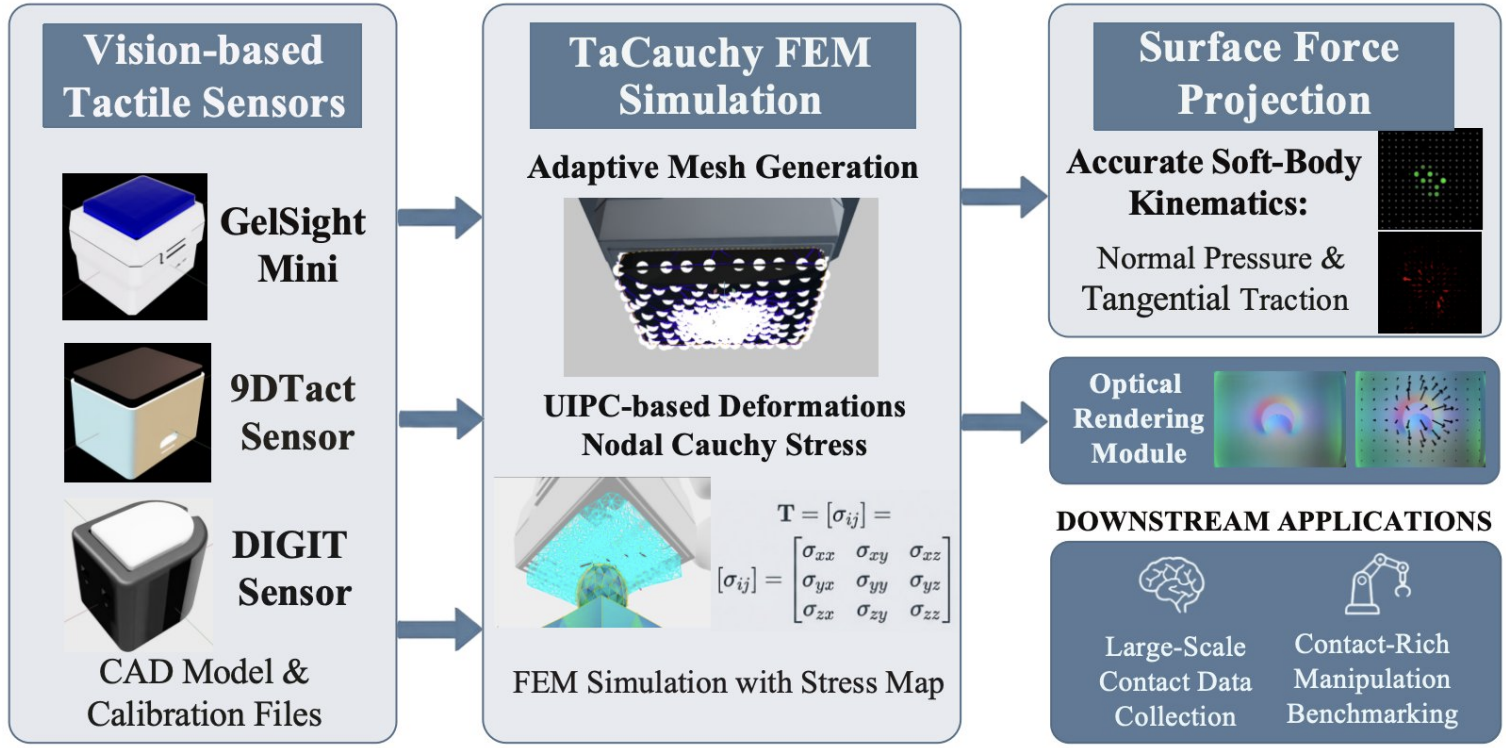
|
IROS 2026 |
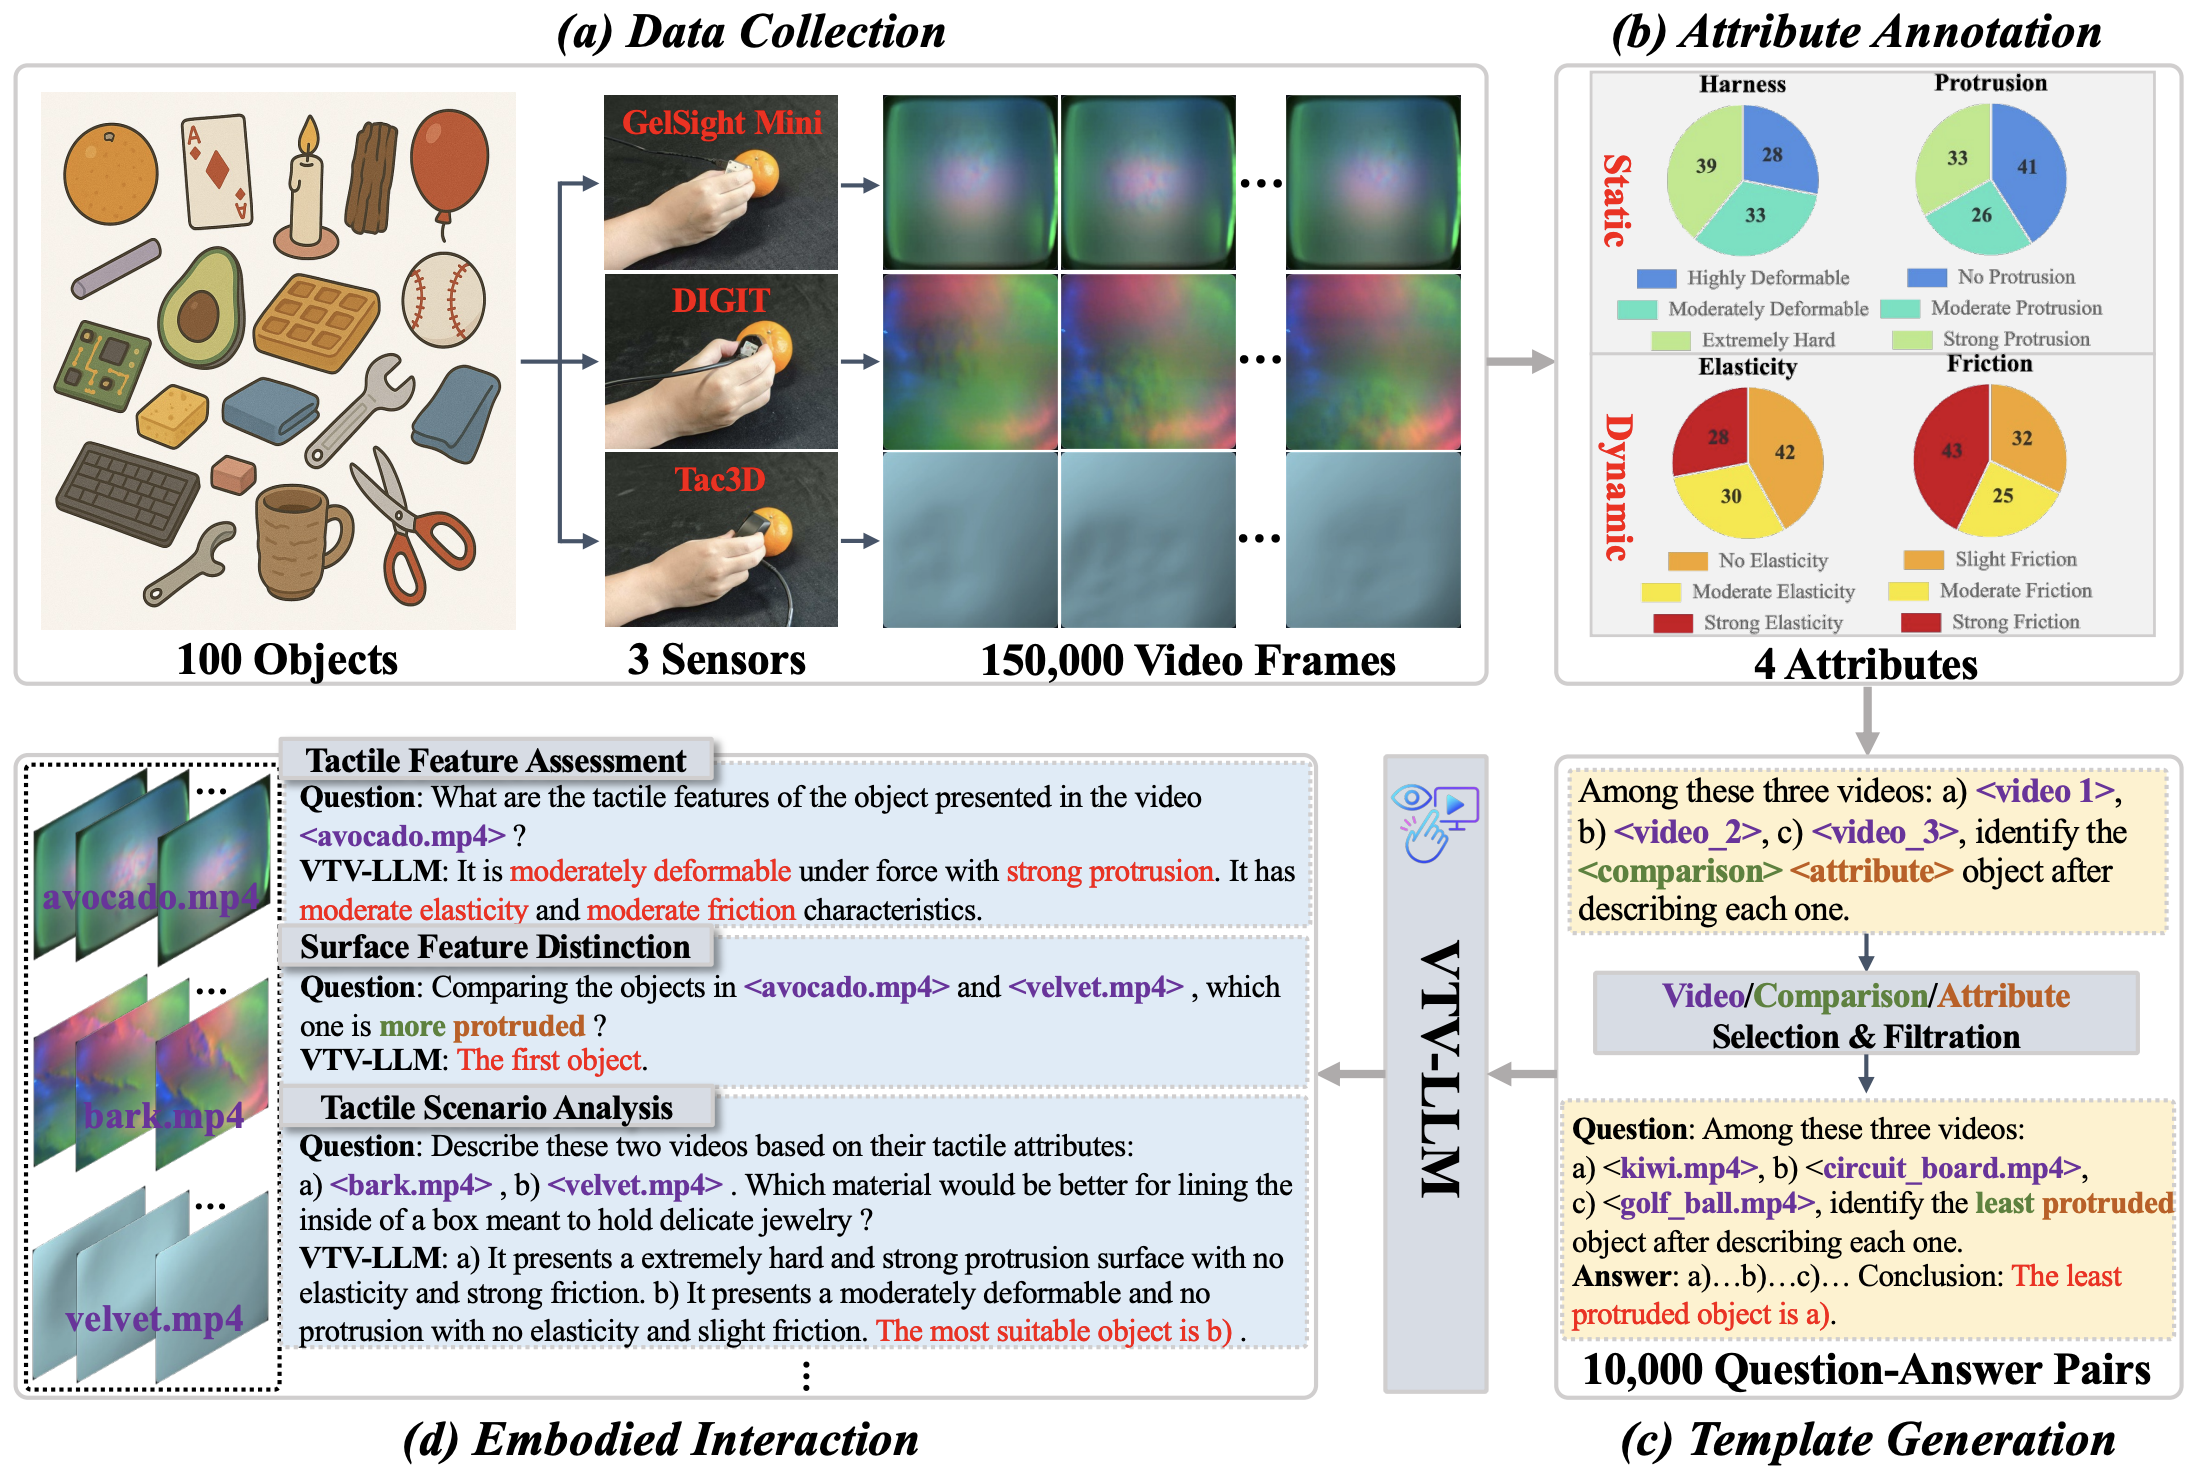
|
NeurIPS 2025 |
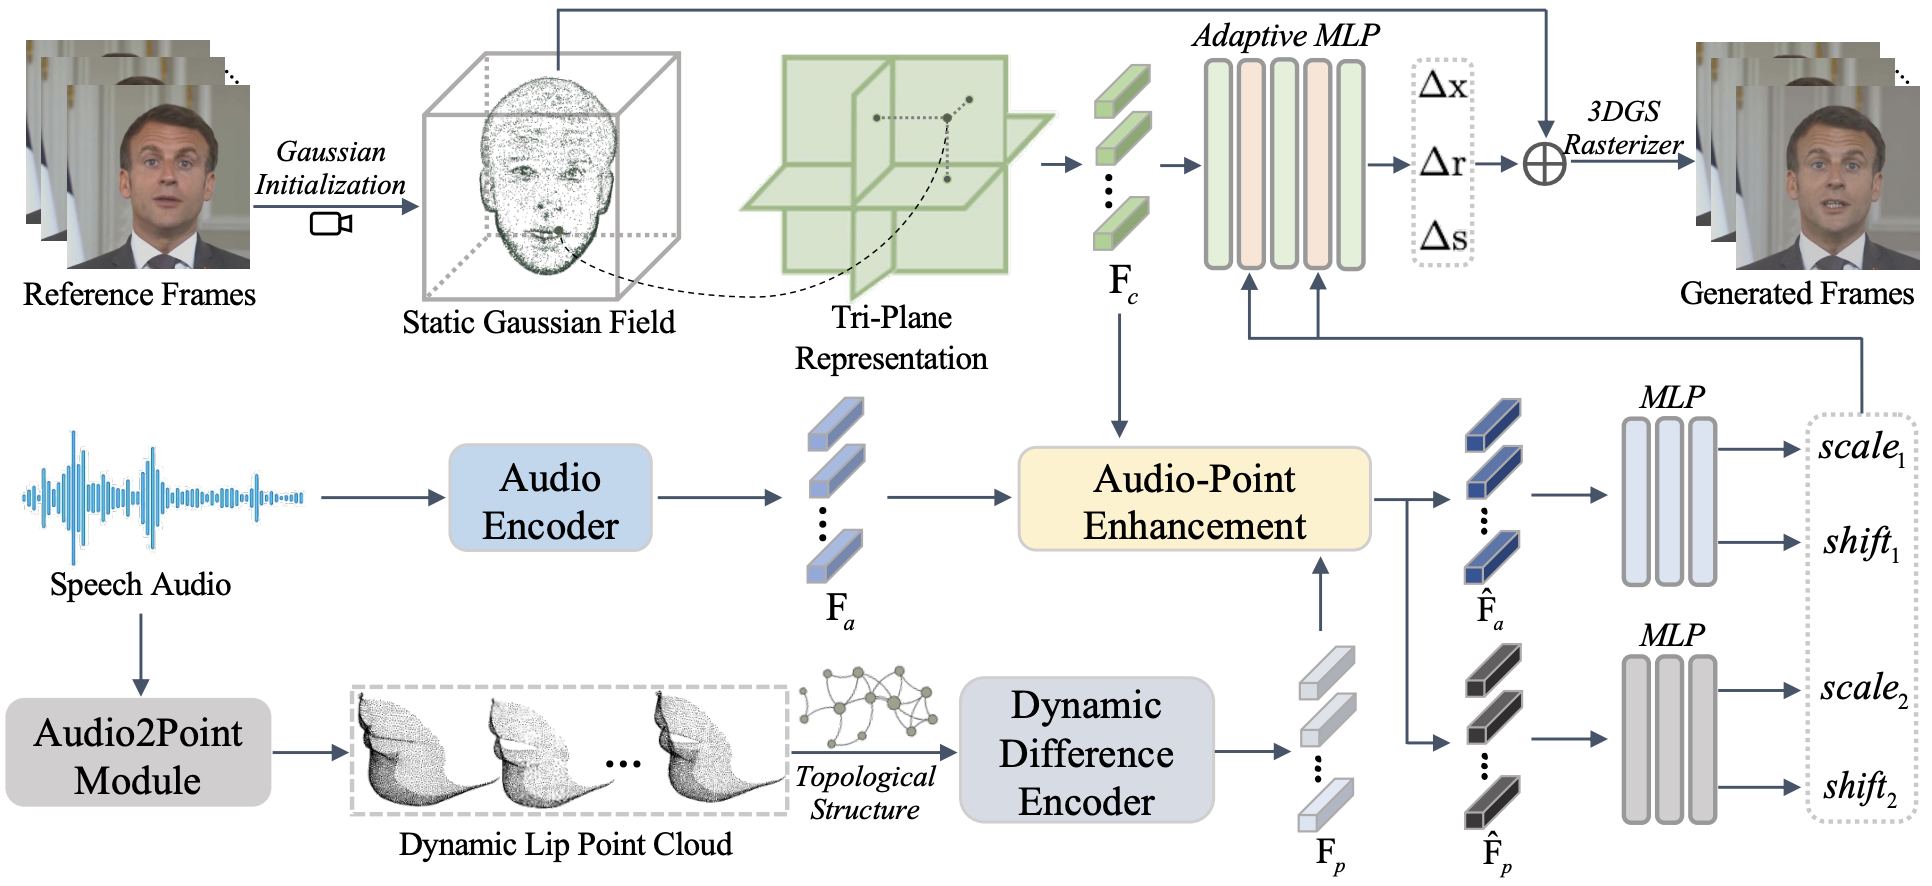
|
AAAI 2025 |
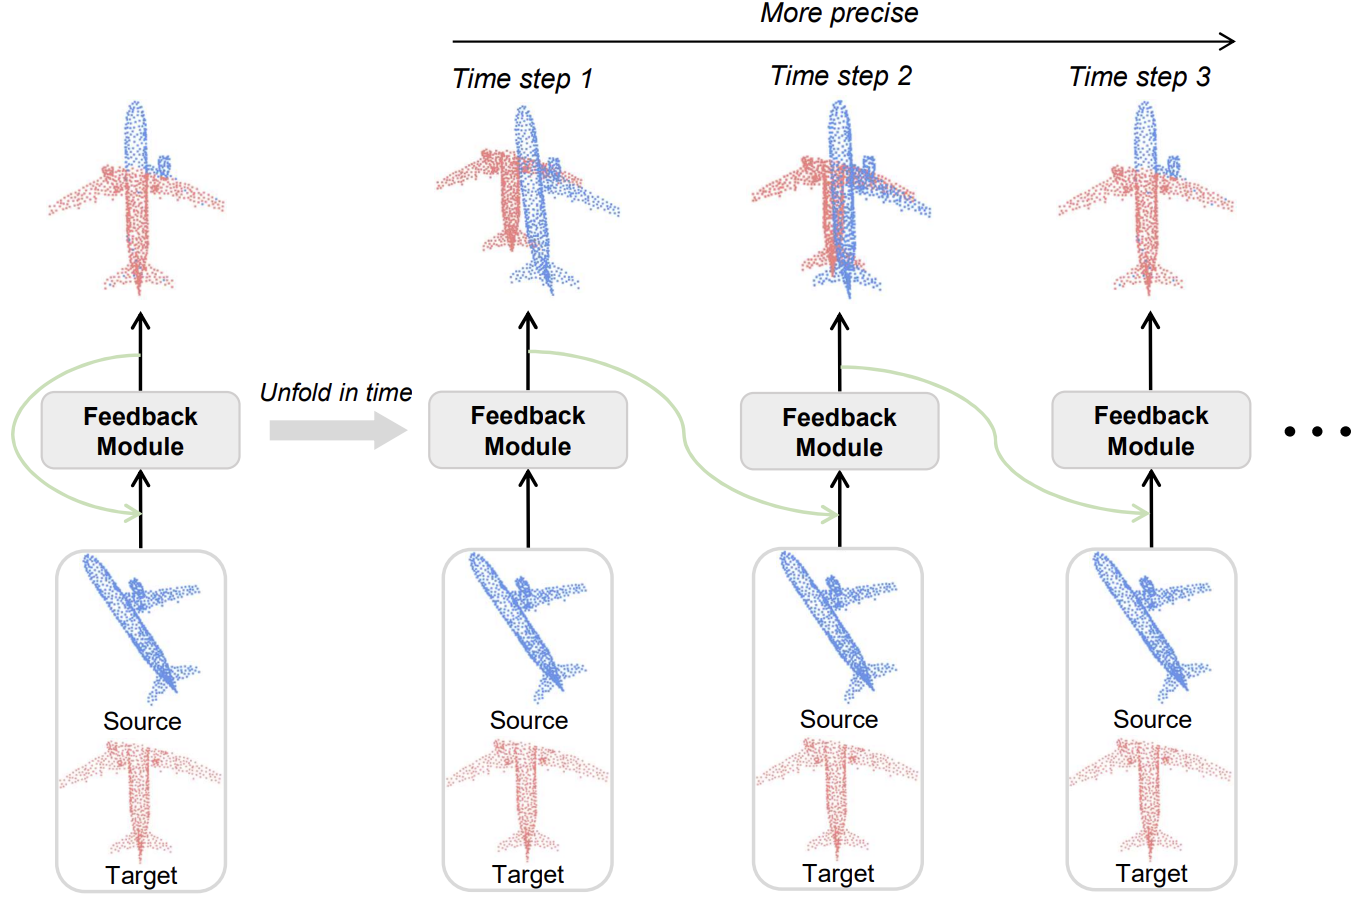
|
IEEE RA-L 2024 |
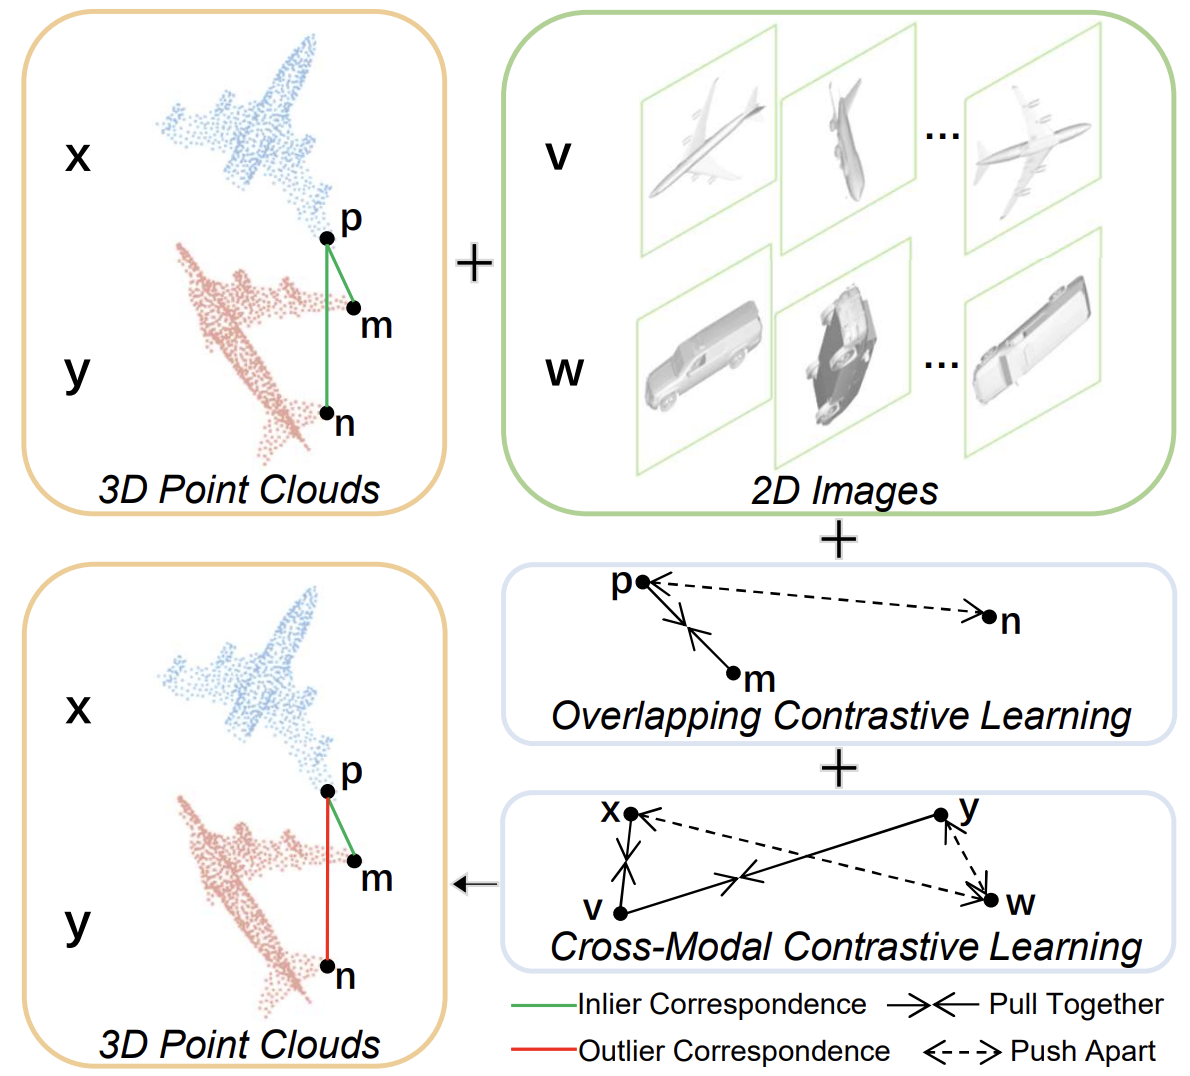
|
IEEE RA-L 2024 |
|
Xiaomi Robotics
2026.05–now Top Talent Program |
|
ByteDance Seed
2025.12–2026.04 Research Intern |

|
X Square Robot
2025.06–2025.11 Research Intern |
- 2026.09 — Future Leaders Scholarship in Tsinghua University
- 2026.06 — WorldArena Challenge@CVPR 2026 3rd Place
- 2025.06 — Outstanding Master's Thesis of Xi'an Jiaotong University
- 2024.10 — National Scholarship
- 2023.10 — Xi'an Jiaotong University Postgraduate Academic Scholarship
